Loading...
Searching...
No Matches
transform.hpp File Reference
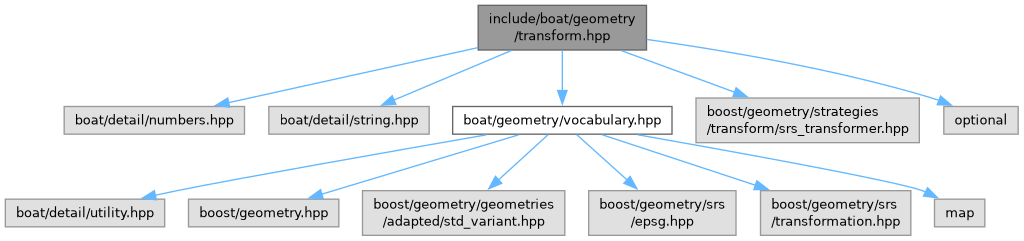
#include <boat/detail/numbers.hpp>#include <boat/detail/string.hpp>#include <boat/geometry/vocabulary.hpp>#include <boost/geometry/strategies/transform/srs_transformer.hpp>#include <optional>
Include dependency graph for transform.hpp:
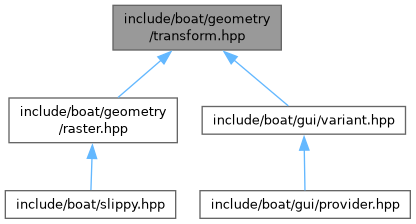
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Namespaces | |
| namespace | boat |
| namespace | boat::geometry |
Typedefs | |
| using | boat::geometry::mat_forward |
Functions | |
| auto | boat::geometry::ortho (geographic::point const &v) |
| Orthographic SRS centered at v. | |
| srs_variant | boat::geometry::to_srs_variant (auto const &meta) |
| Prefers a positive epsg code to proj4; throws if neither is available. | |
| auto | boat::geometry::transformation (srs_spec auto const &a, srs_spec auto const &b) |
| Creates a transformation from source a to target b. | |
| auto | boat::geometry::transformation (srs_spec auto const &v) |
| Creates a transformation from WGS 84 longitude/latitude to v. | |
| template<projection_or_transformation T> | |
| auto | boat::geometry::srs_forward (T const &v) |
| template<projection_or_transformation T> | |
| auto | boat::geometry::srs_inverse (T const &v) |
| auto | boat::geometry::mat_inverse (matrix const &v) |
| template<tagged T1, same_tag< T1 > T2, class Strategy> | |
| bool | boat::geometry::transform (T1 const &geom1, T2 &geom2, Strategy const &strategy) |
| auto | boat::geometry::transform (auto const &... strategies) |
| Composes strategies and returns std::nullopt if a transformation fails. | |